


Designing UVC LED Modules into Disinfection Robots
 Disinfection Robotics Series
 Designing UVC LED Modules into Disinfection Robots: The AMR Engineering Playbook
1. Why the Disinfection Robot Is the Ideal Carrier for UVC LED
Mercury lamps survived on walls because they never had to move. Put them on a mobile platform and every advantage disappears. The table below summarizes the five dimensions where the difference shows up in a robot build.
| Dimension | Mercury lamp | UVC LED module |
|---|---|---|
| Shock & vibration | Fragile glass tube; breaks on impact | Solid-state; no filament or glass envelope |
| Startup | Slow restrike; needs ballast warm-up | Instant full output in microseconds |
| On/off cycling | Frequent cycling shortens lamp life | Designed for rapid cycling with minimal penalty |
| Volume & weight | Bulky tube + ballast + reflectors | Compact; up to approximately 60% volume reduction (typical reference range; depends on power class and optics; must be validated) |
| Supply voltage | High-voltage ballast required | Low-voltage DC; battery-friendly |
The design consequence: the robot chassis no longer needs to protect a fragile lamp or carry a ballast. The freed space and weight can go to batteries, sensors, or a larger UV aperture — the module becomes a design input instead of a design constraint.
2. Design Gate 1: Light Pattern and Coverage
A stationary lamp only needs to cover one room. A robot must cover whatever it drives past — and it is moving while it does so.
Dose is a moving-target calculation
The delivered dose is Dose (mJ/cm²) = Irradiance (mW/cm²) × Exposure Time (s). On a robot, exposure time is set by the robot's speed and dwell pattern, not by an operator. A robot that passes a surface at 0.5 m/s delivers less dose than one that stops for 30–60 s. That means the module's irradiance and light pattern must be specified backwards from the robot's mission profile — not the other way around.
Multi-face arrays avoid shadow zones
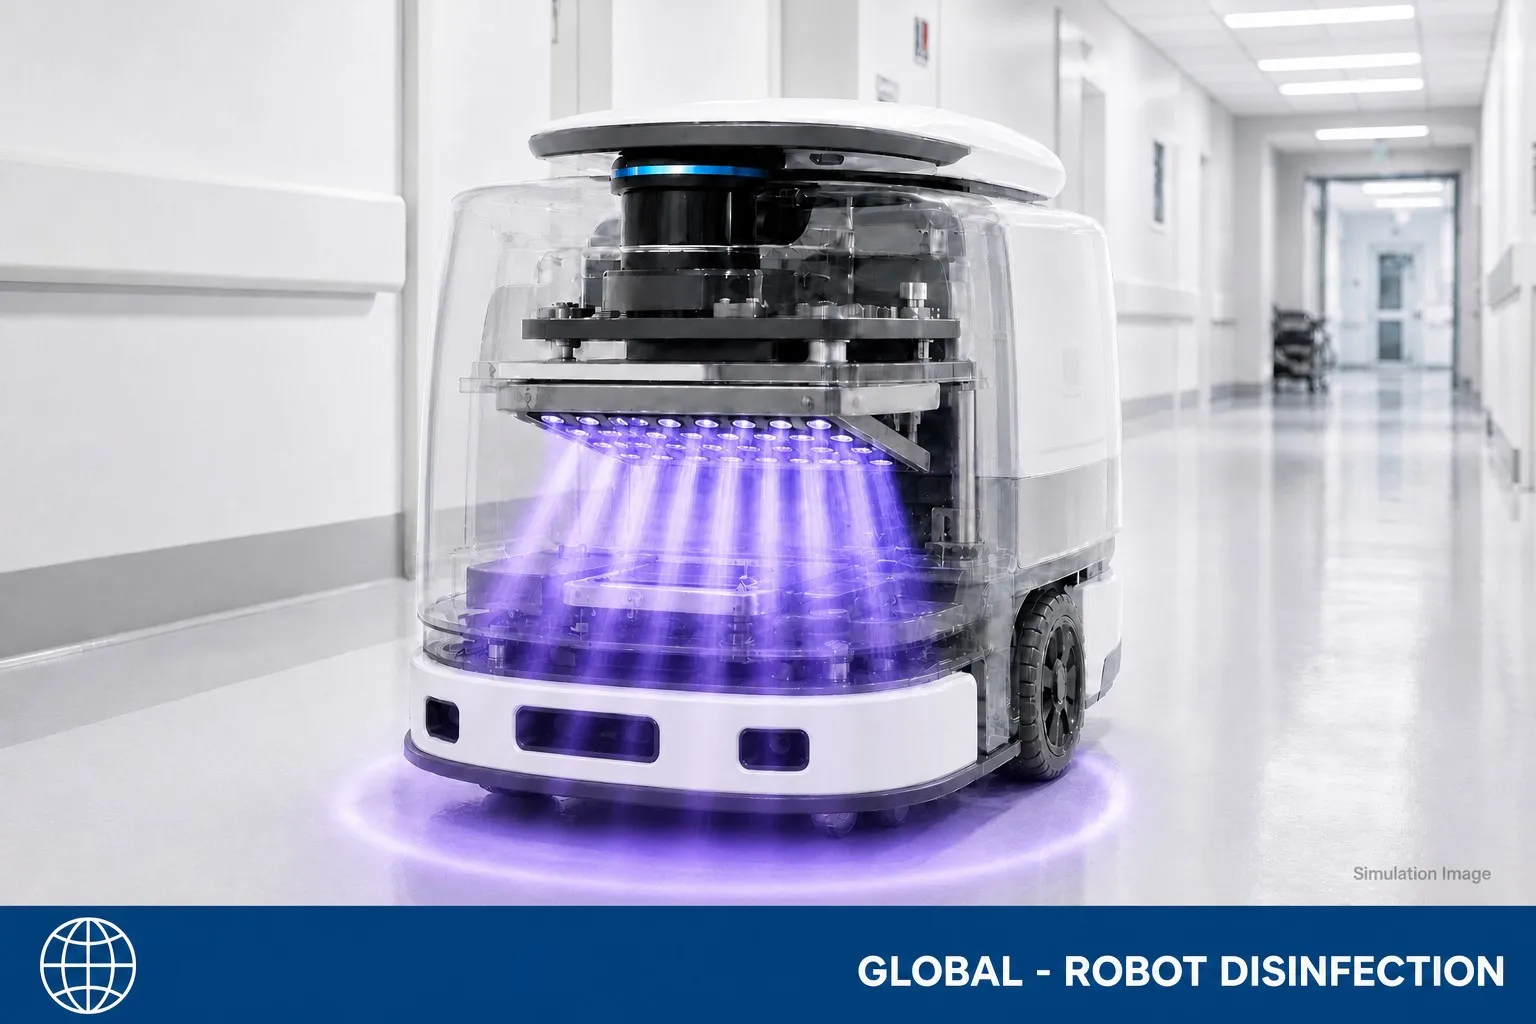
A single downward-facing panel leaves shadows under chairs, bed frames, and equipment. Robots that need true coverage use multi-face arrays — top, sides, and bottom — so light reaches surfaces regardless of angle. The trade-off is power budget: more faces mean more diodes and more heat to manage (see Gate 2).
Why ±3nm binning matters on a moving platform
Dose consistency across the coverage area depends on wavelength consistency across the array. If some diodes sit off-peak, parts of the coverage area receive less germicidal energy — and on a moving robot those inconsistencies are hard to debug because the exposure window is short. Precision binning (±3nm) locks every diode to the same spectral window so the whole array behaves identically, everywhere on the path.
3. Design Gate 2: Instant On/Off and Thermal Shock
A disinfection robot's mission profile is a series of stops: arrive, dwell 30–60 s (typical mission profiles; your parameters will differ), move, dwell again. That is exactly the pattern that punishes mercury lamps and rewards LEDs.
The advantage: instant, lossless cycling
An LED reaches full output in microseconds and can be cycled thousands of times without the restrike penalty of a mercury lamp. The robot can switch the array on only when it is actually in a dwell position — saving energy and lamp-hours automatically.
The cost: thermal cycling on the junction
Every on/off cycle pushes the LED junction (Tj) through a temperature swing. UV LED output falls as junction temperature rises — typical sensitivity is on the order of 1–2% optical output reduction per 10 K junction rise (reference range; validate for your module). In a mobile chassis with limited space, the heat path must be designed for the peak drive condition, not the average — because the robot's stop-and-go pattern creates repeated thermal transients.
4. Design Gate 3: Lifetime and Maintenance
Fleet robots run 24/7. Downtime is lost revenue, and lamp replacement on a moving platform is worse than on a wall — the unit must be pulled from service.
- Rated life under rated conditions. Modules are rated for 50,000 hours of continuous operation under rated operating conditions. Actual life depends on drive current, chassis thermal management, and duty cycle — match the rating to your maintenance cycle.
- Flip-chip removes the wire-bond failure mode. Wire bonds break under vibration and thermal cycling — the two stresses a robot applies constantly. Flip-chip (no gold wires) plus inorganic packaging (AlN ceramic substrate, quartz window) survives the mobile environment that would fatigue a conventional package.
- Plug-in modular design. Field-swappable modules let a service tech replace a failed array in minutes without sending the whole robot back — the difference between a 10-minute stop and a 3-day outage.
5. The Six-Parameter Selection Checklist for Robot OEMs
When you evaluate a UVC LED module for your robot, put these six numbers on paper. A supplier that asks for them is doing engineering; a supplier that does not is selling components.
- Wavelength (265nm / 275nm, or dual-band). 265nm is near the DNA absorption peak; 275nm produces less ozone. The choice follows your target pathogens and certification requirements.
- Power density (mW/cm² at target distance). Must be specified at the actual working distance of the robot — not at the lens surface.
- Beam angle and light pattern. Matched to your coverage geometry: wide for room coverage, tight for focused dwell zones.
- Thermal interface. What heat sink or cold plate does the module expect? Does the robot chassis provide it?
- Control signal (PWM / 0–10 V / digital). Does your robot controller already speak it? Confirm dimming range and response time.
- Mechanical envelope. Exact dimensions, mounting points, and connector position — does it fit your chassis without redesign?
Frequently Asked Questions
Q1: Does a robot that drives through a room actually disinfect the surfaces?
It depends on the delivered dose, which depends on the module's irradiance and the robot's speed and dwell pattern. A robot can deliver a designed dose only if the module, optics, and motion profile are engineered together. Never assume a specific disinfection rate — validate dose delivery against your robot's actual mission profile.
Q2: Which wavelength is better for a robot — 265nm or 275nm?
It depends on your target microorganisms and your ozone policy. 265nm is near the DNA absorption peak (highest germicidal efficiency per photon); 275nm produces less ozone, which matters in enclosed, occupied spaces. Some robots use dual-wavelength arrays (265+275nm) to balance both. Validate the choice against your target pathogens and certification requirements.
Q3: Why is ±3nm binning important for our array?
Because dose consistency across the coverage area depends on wavelength consistency across the array. Off-peak diodes deliver lower germicidal efficiency, creating uneven disinfection. Binning locks every diode to the same window so the whole array behaves identically.
Q4: Can we use our robot's existing controller to drive the modules?
Most UVC LED modules accept standard control signals — PWM, 0–10 V, or digital dimming. Confirm the interface and dimming range with your supplier, and verify that your controller firmware supports the modulation needed for presence-based disinfection.
Q5: How long will the module last in a 24/7 fleet?
Modules are rated for 50,000 hours of continuous operation under rated operating conditions. Actual life depends on drive current, thermal management in your chassis, and duty cycle. Match the rated life to your maintenance cycle and validate with your supplier for your operating profile.
Q6: Is flip-chip really necessary for robots?
It removes the wire-bond failure mode that is most sensitive to vibration and thermal cycling — the two stresses a robot applies constantly. For a mobile platform, flip-chip plus inorganic packaging is the difference between a spec-sheet life and a life that survives the real world. The decision is engineering judgment, not marketing.
Q7: Does Tianhui supply modules specifically for disinfection robots?
Tianhui supplies UVC LED modules and arrays for OEM disinfection applications, with wavelength options (265nm/275nm), precision binning, and inorganic packaging built for demanding environments. Confirm the specific configuration for your robot with our engineering team.
Conclusion
The disinfection robot is the ideal carrier for UVC LED — but only when the module is designed for the platform. Light pattern must follow the robot's path, thermal design must survive its stop-and-go rhythm, and lifetime must match a 24/7 fleet. Ask the six questions, and the module stops being a component and becomes the light engine your robot was built around.
Related Reading: Why UV LED Mosquito Trap Tubes Look Different: The Perception Guide — the perception science behind UV LED color and performance.